KonARM - mobile robot manipulator
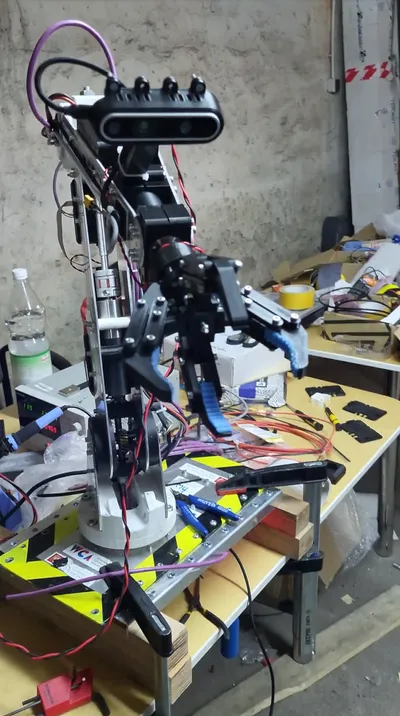
complete4-axis manipulator for mobile robot Ariadna.
- electronics
- embedded
- robotics
- c
- cpp
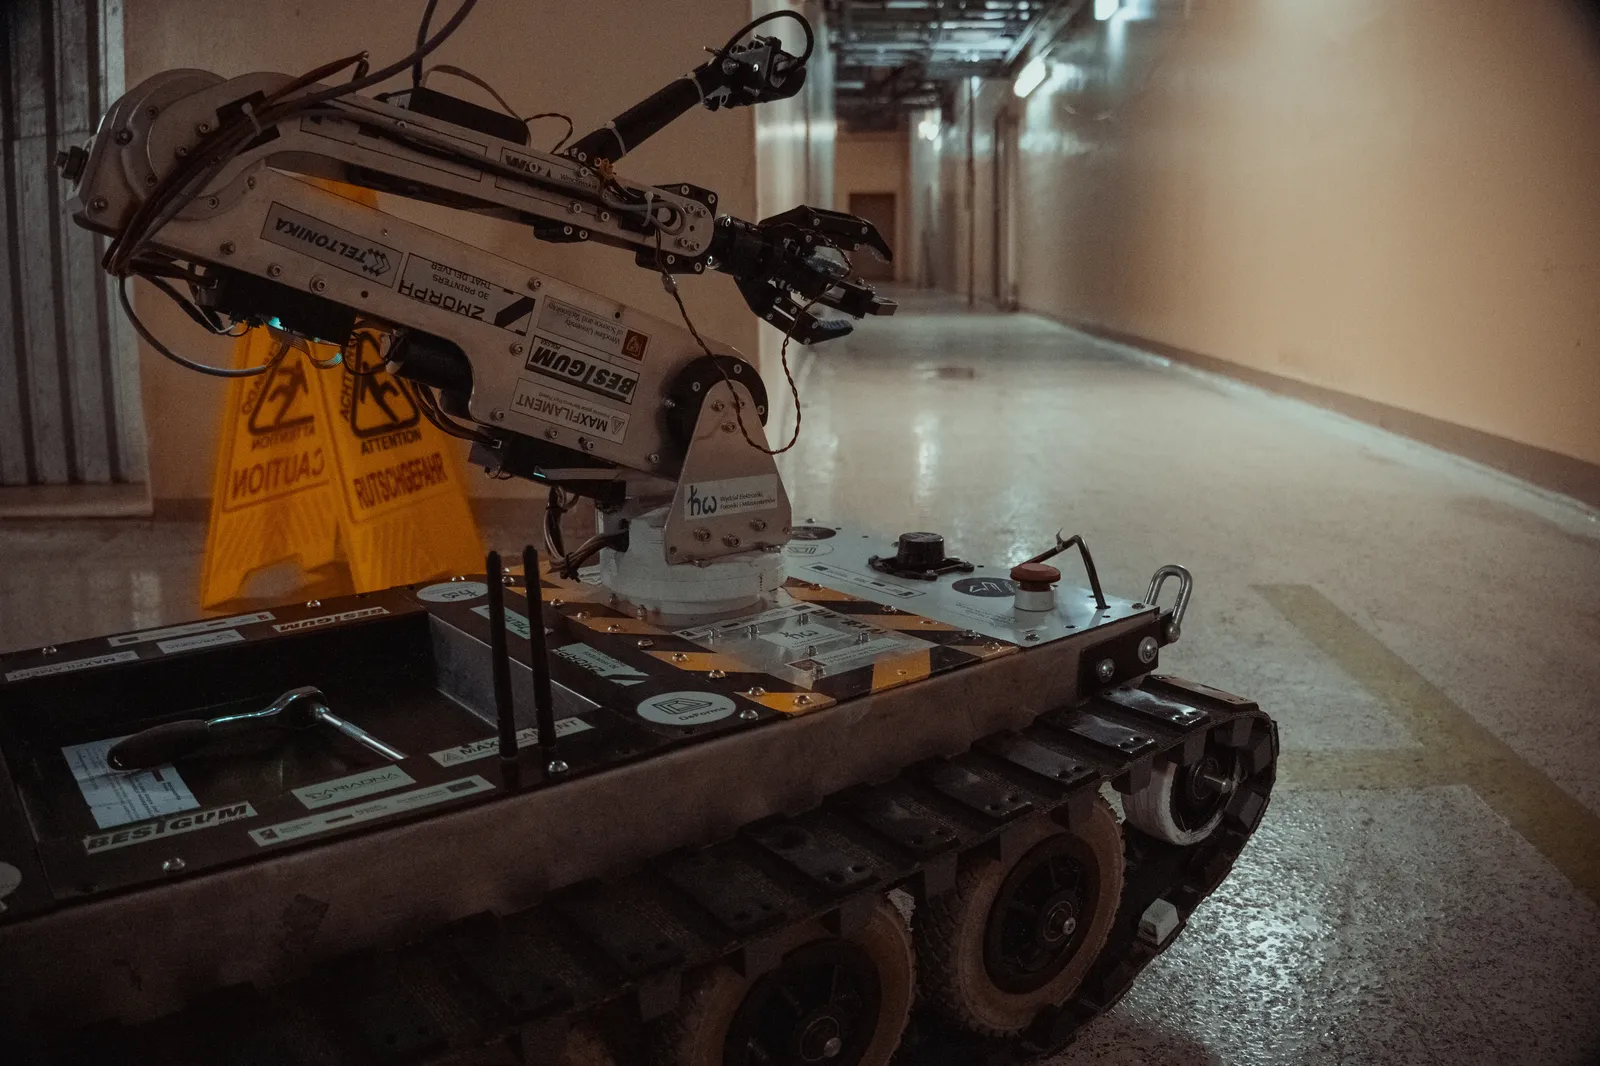
current state
Manipulator works in position control mode. It took part mounted on the robot in few robotics competitions. Finally the Ariadna robot project has been archived and replaced by NOMAD project.
specifications
- Degrees of freedom
- 4
readme
Project origin
KonARM started as standalone manipulator, but then became a sub-project of Ariadna robot developed at KoNaR Robotics Scientific Club at Wrocław University of Science and Technology.
My role in the project
I was responsible for developing firmware for Joint Controller. It realized closed-loop position control of a DC motor with feedback from absolute and incremental encoders. The communication was based CanBus.
Footage
no entries yet