T.R.I.O.D.A. - the robodog
activeQuadruped robot project.
- control
- electronics
- embedded
- robotics
- ros2
- stm32
- cpp
- python
current state
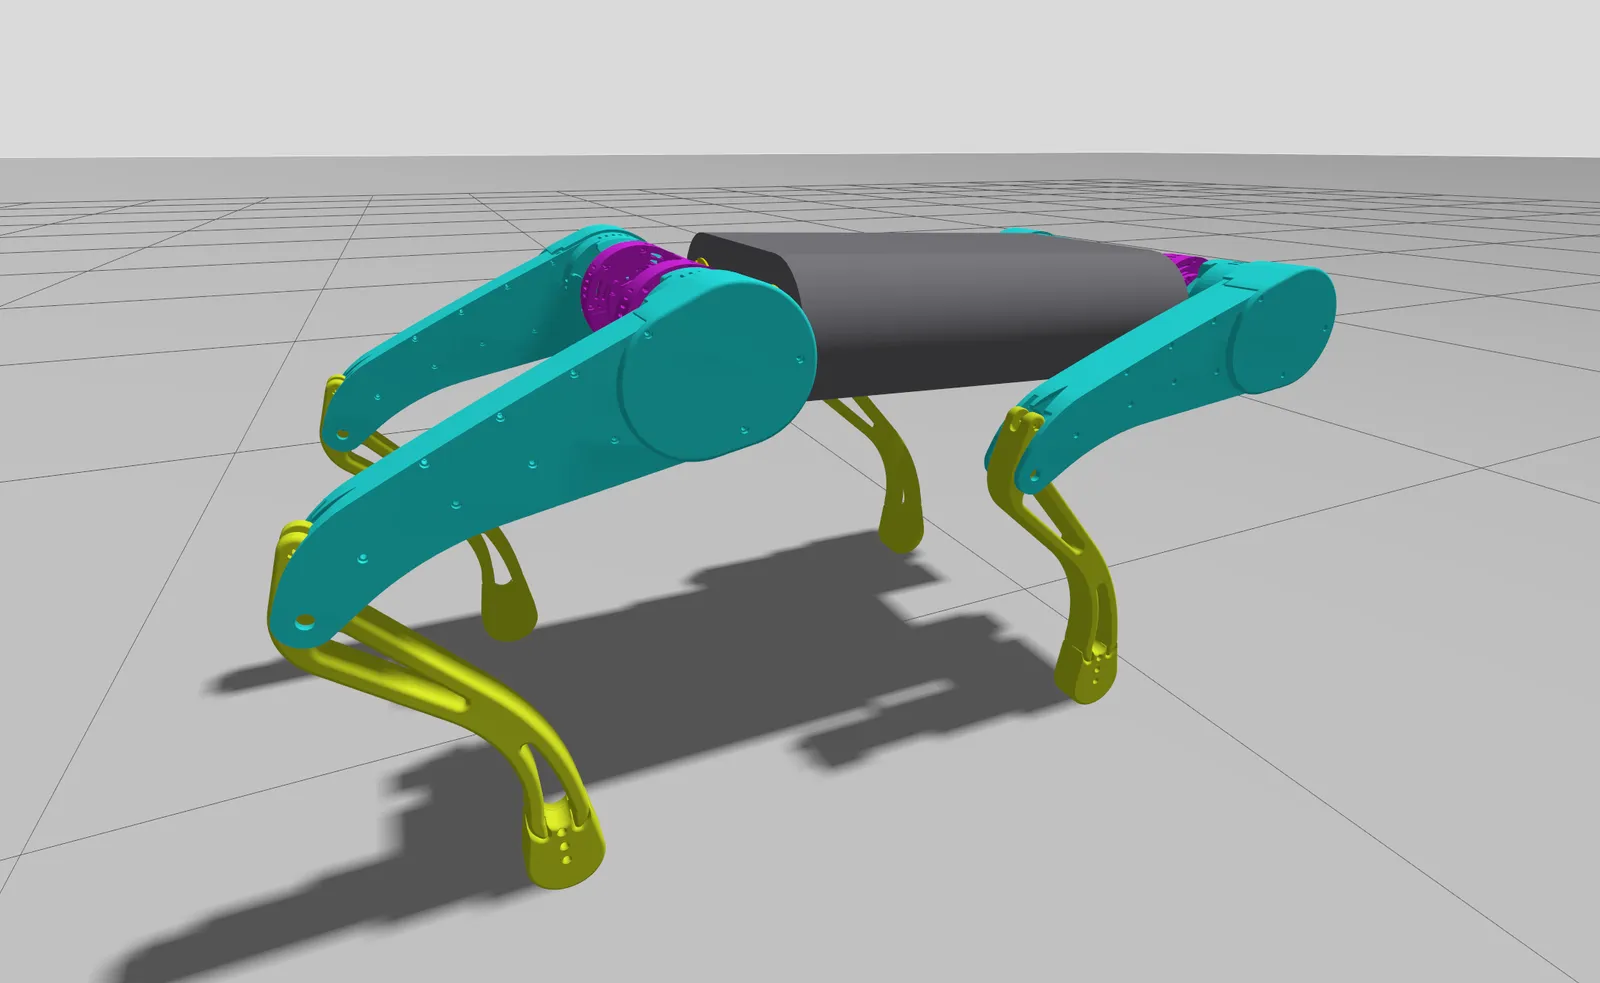
Custom QDD actuator with dedicated BLDC controller pcb has been developed and give satisfying results. Progress on building the robot seats now on 3D printed 3-DoF leg. The leg is currently being integrated with ROS2.
specifications
- Degrees of freedom
- 12
readme
Project origin
The project has emerged from existential urge of group of robotics graduates to finally build a humanoid robot. To approach the subject of walking robots more easily, we decided to start with quadruped robot. Name of the robot comes from team member's dog (biological one) - Dioda. Trioda as also a term from electronics fits as next step in life form evolution.
Robot model
Robot leg
Mechanical construction leg for our robodog has been designed and assembled by Kamil - project's main mechanics engineer. Leg is built around custom QDD actuators described below. Currently durability tests are being conduced in parallel to ROS2 integration.
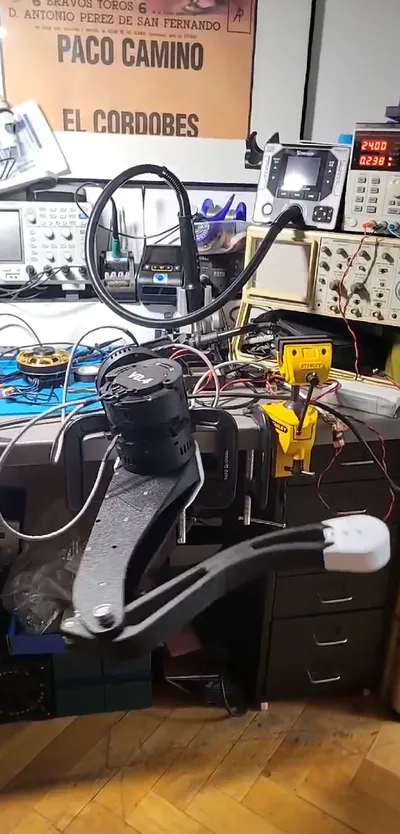
Custom QDD actuator
As a base for robot leg joints a custom QDD (Quasi Direct Drive) actuator has been developed. Main parts of the actuator are: GIM-8108 pancake style BLDC motor with integrated 8:1 planetary reduction, shell made of ABS and custom FOC controller paired with second encoder after the reduction.
Custom FOC controller
To drive BLDC motor located in the custom QDD actuator an FOC (Field Oriented Control) controller was needed. To provide maximal solution flexibility and gain experience in controlling such devices a custom pcb has been designed. It is classical 3-phase inverter design based around DRV8353 smart gate driver and STM32H563 microcontroller. PCB has been designed as 6-layer board with controlled impedance. Position feedback is acquired from 2 magnetic sensors: on-axis one aligned with motor and off-axis one mounted after the gearbox providing calibrationless startup. Firmware is based on Zephyr Operating System.